RESEARCH DIRECTION / 03
Uncertainty Quantification
Understanding the reliability of a robot’s geometric estimates.
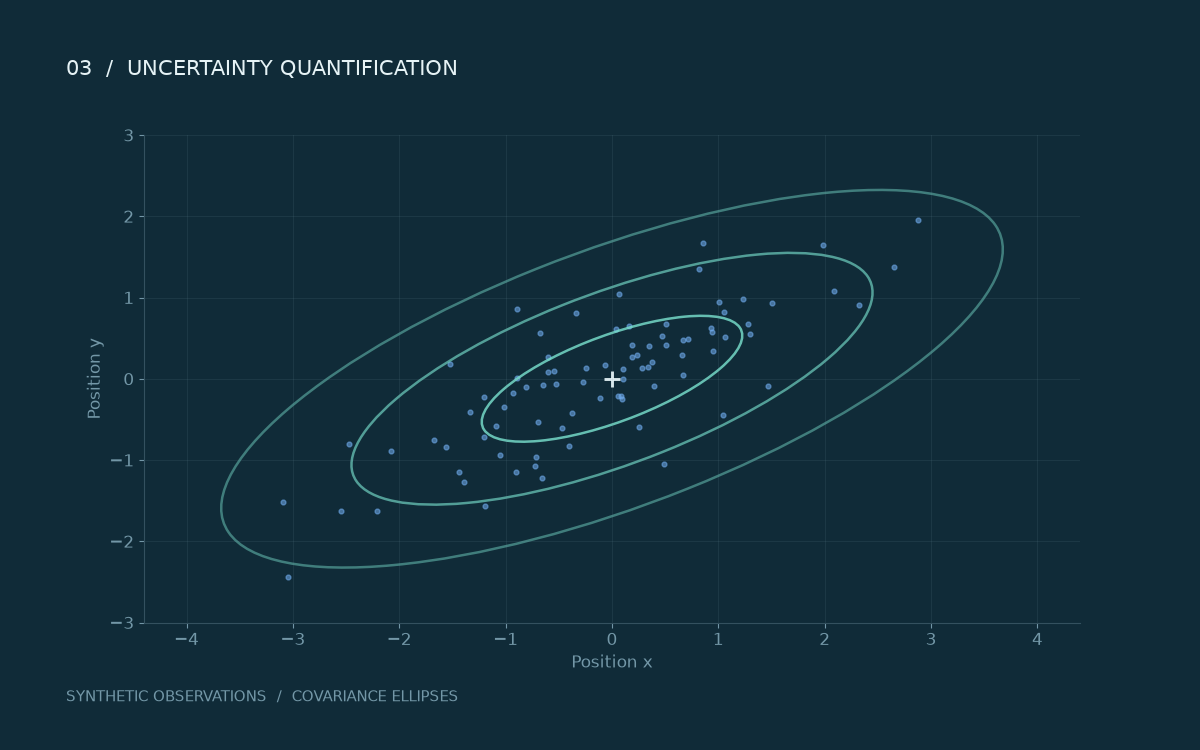
Conceptual illustration: synthetic observations and covariance ellipses. Not an experimental result.
Beyond a single estimate
A perception system produces an estimate of the world from imperfect observations. I am interested in understanding the uncertainty associated with that estimate as part of building safe and scalable robotic perception.
This interest connects naturally to sensor-agnostic perception: different sensing modalities provide different information, and their limitations need to be considered when reasoning about geometry.
Questions I want to explore
- How can uncertainty be represented meaningfully in 3D geometric perception?
- How should a system account for differences in the reliability of its observations?
- How can uncertainty inform the interpretation of a perception result?
A connection to robust estimation
Uncertainty and outlier robustness address related questions about the trust we place in measurements. My GNC series records my study of robust costs, measurement weights, and continuation methods.