RSS 2025
Outstanding Student Paper Award Finalist ↗Doppler Correspondence: Non-Iterative Scan Matching With Doppler Velocity-Based Correspondence
Finding correspondences through motion, beyond spatial proximity.
* Equal contribution · 공동 제1저자
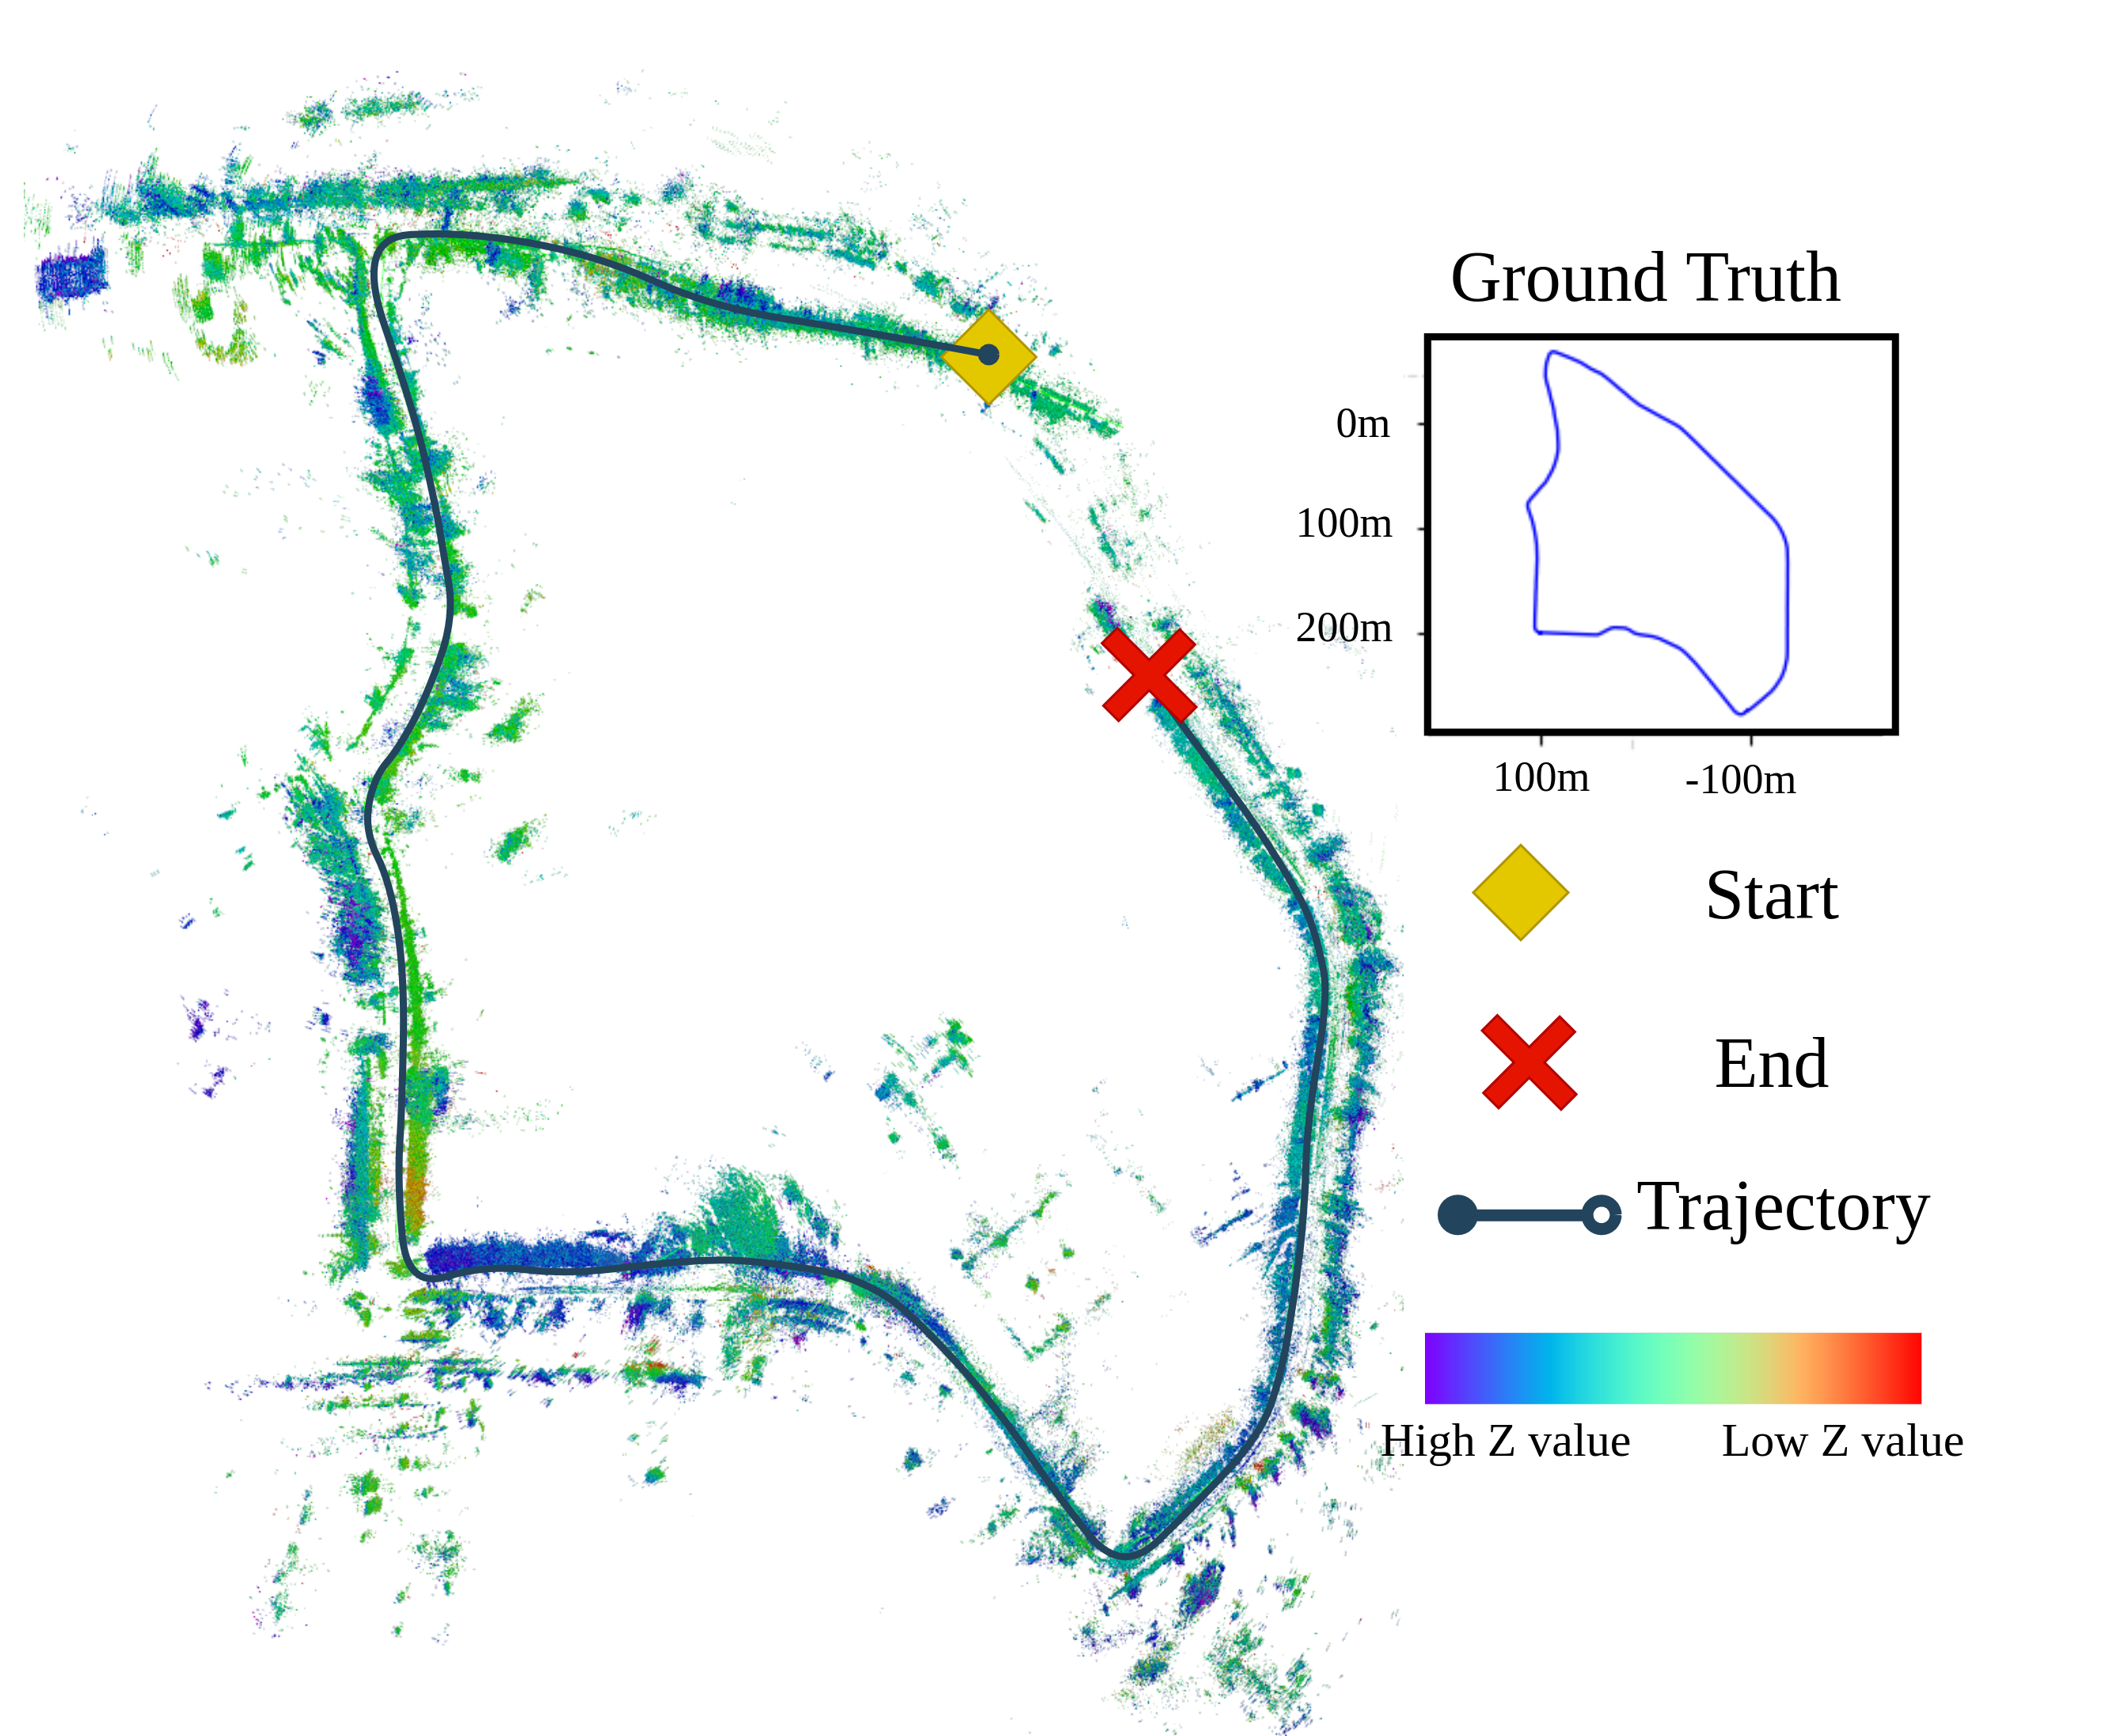
한국어 요약
문제: 가까운 점이 항상 같은 점일까?
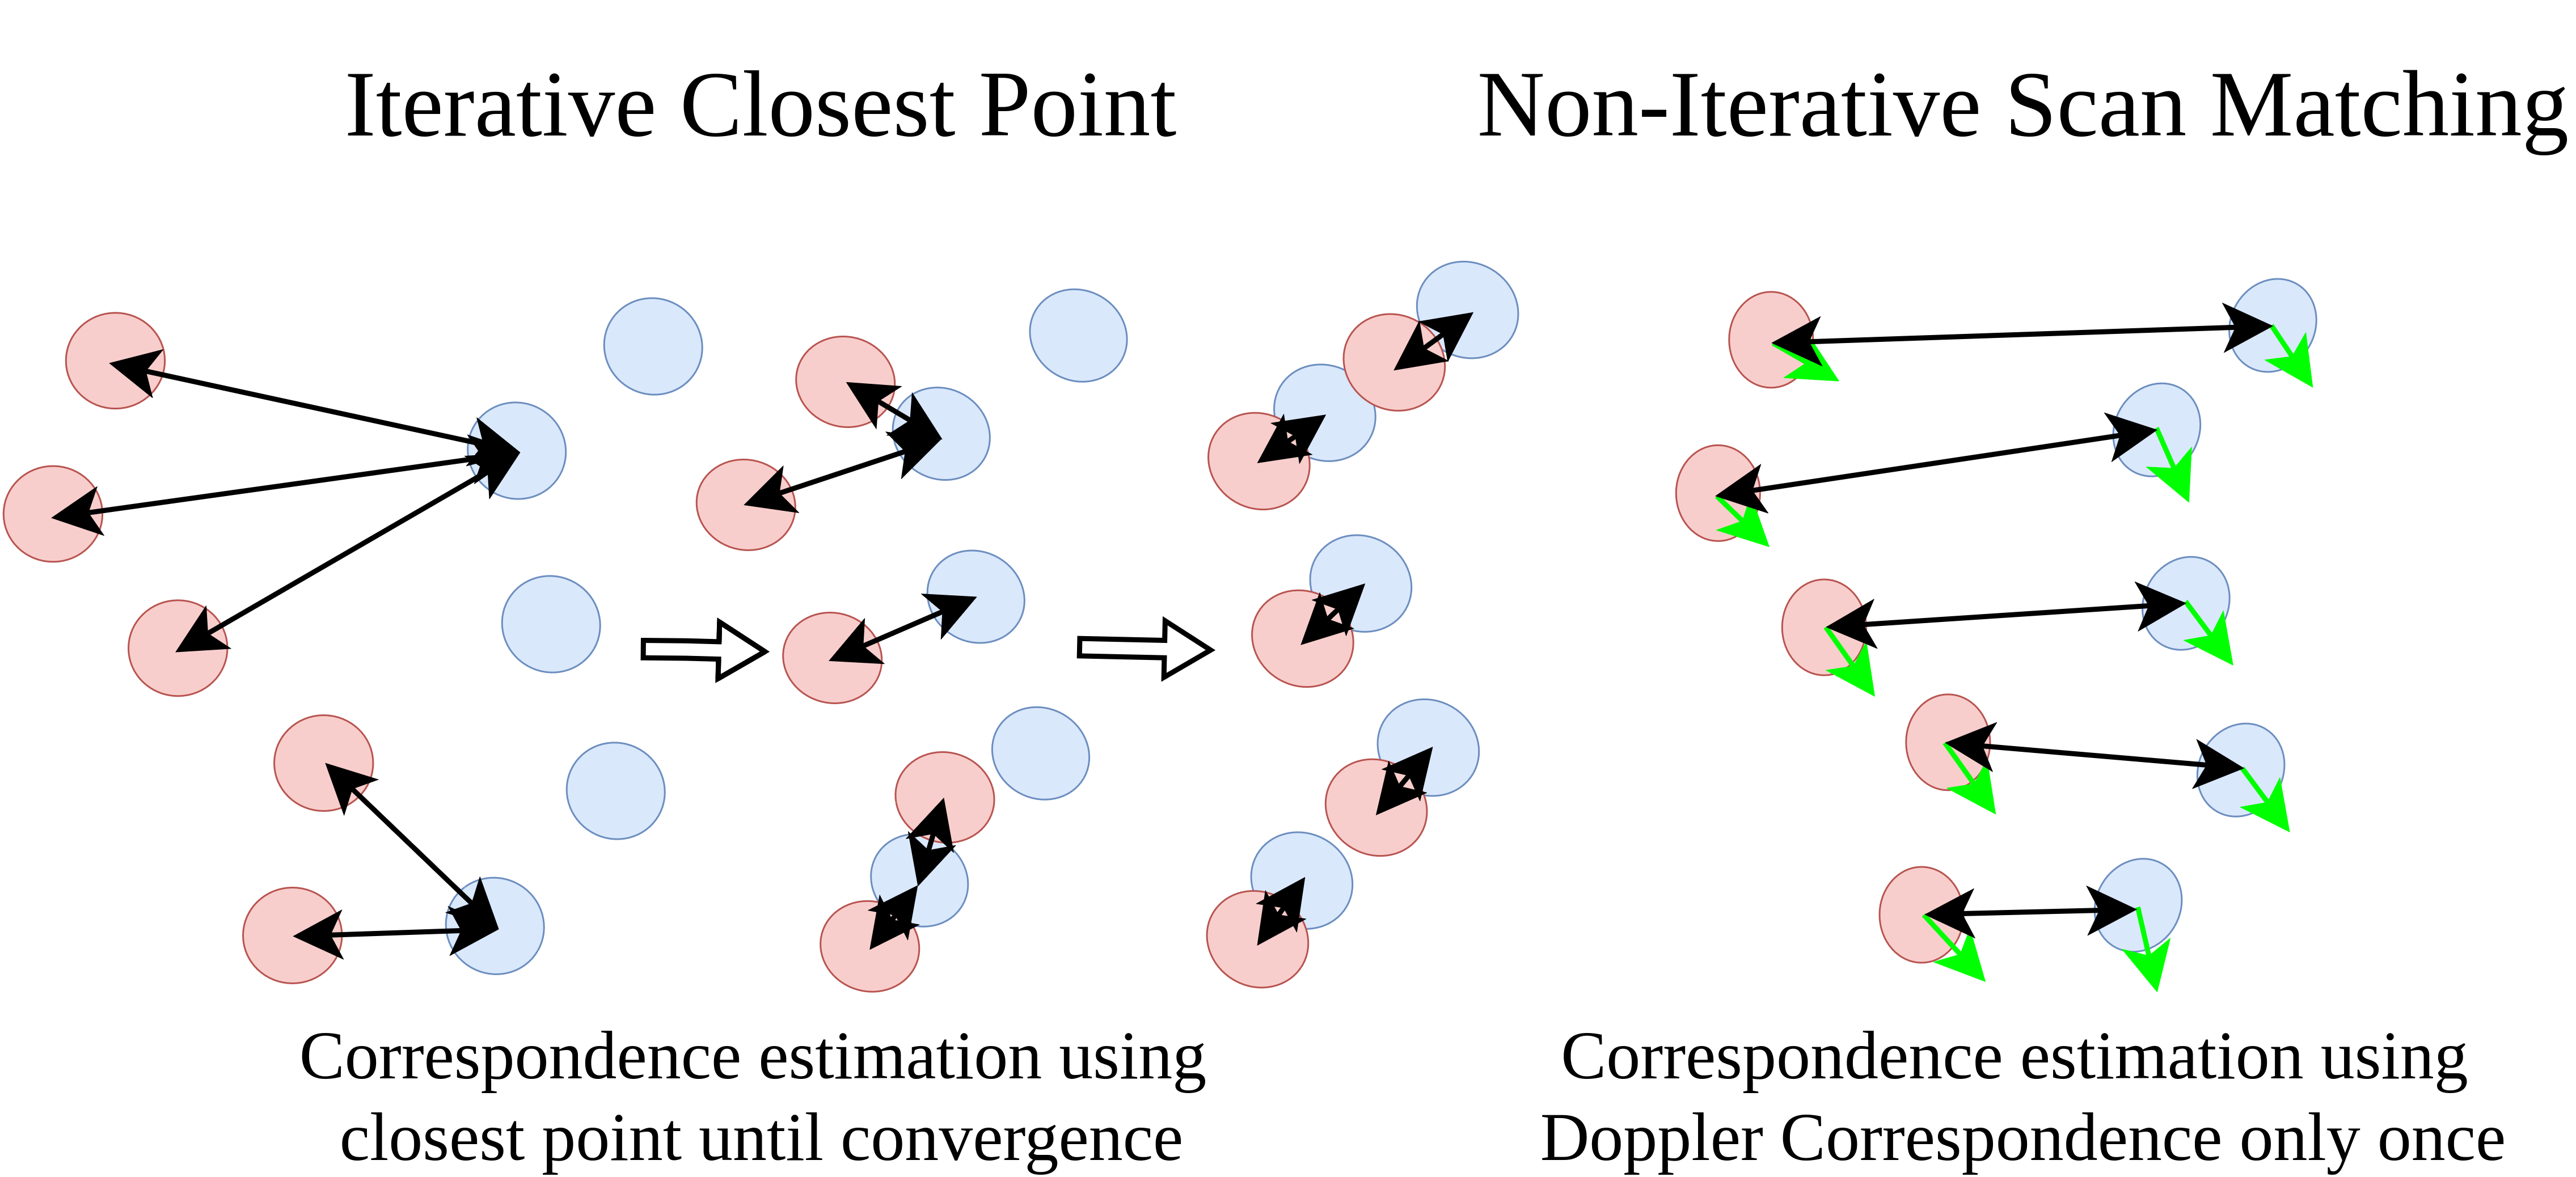
ICP는 두 스캔에서 공간적으로 가까운 점을 연결하고, 자세를 갱신하며 이 과정을 반복합니다. 하지만 벽이나 터널처럼 구조가 반복되거나 점군이 희소하면, 거리만으로는 올바른 대응점을 구별하기 어렵습니다. 이 연구는 4D Radar와 FMCW LiDAR가 제공하는 Doppler 속도를 대응점 탐색에 직접 활용합니다.
핵심 아이디어
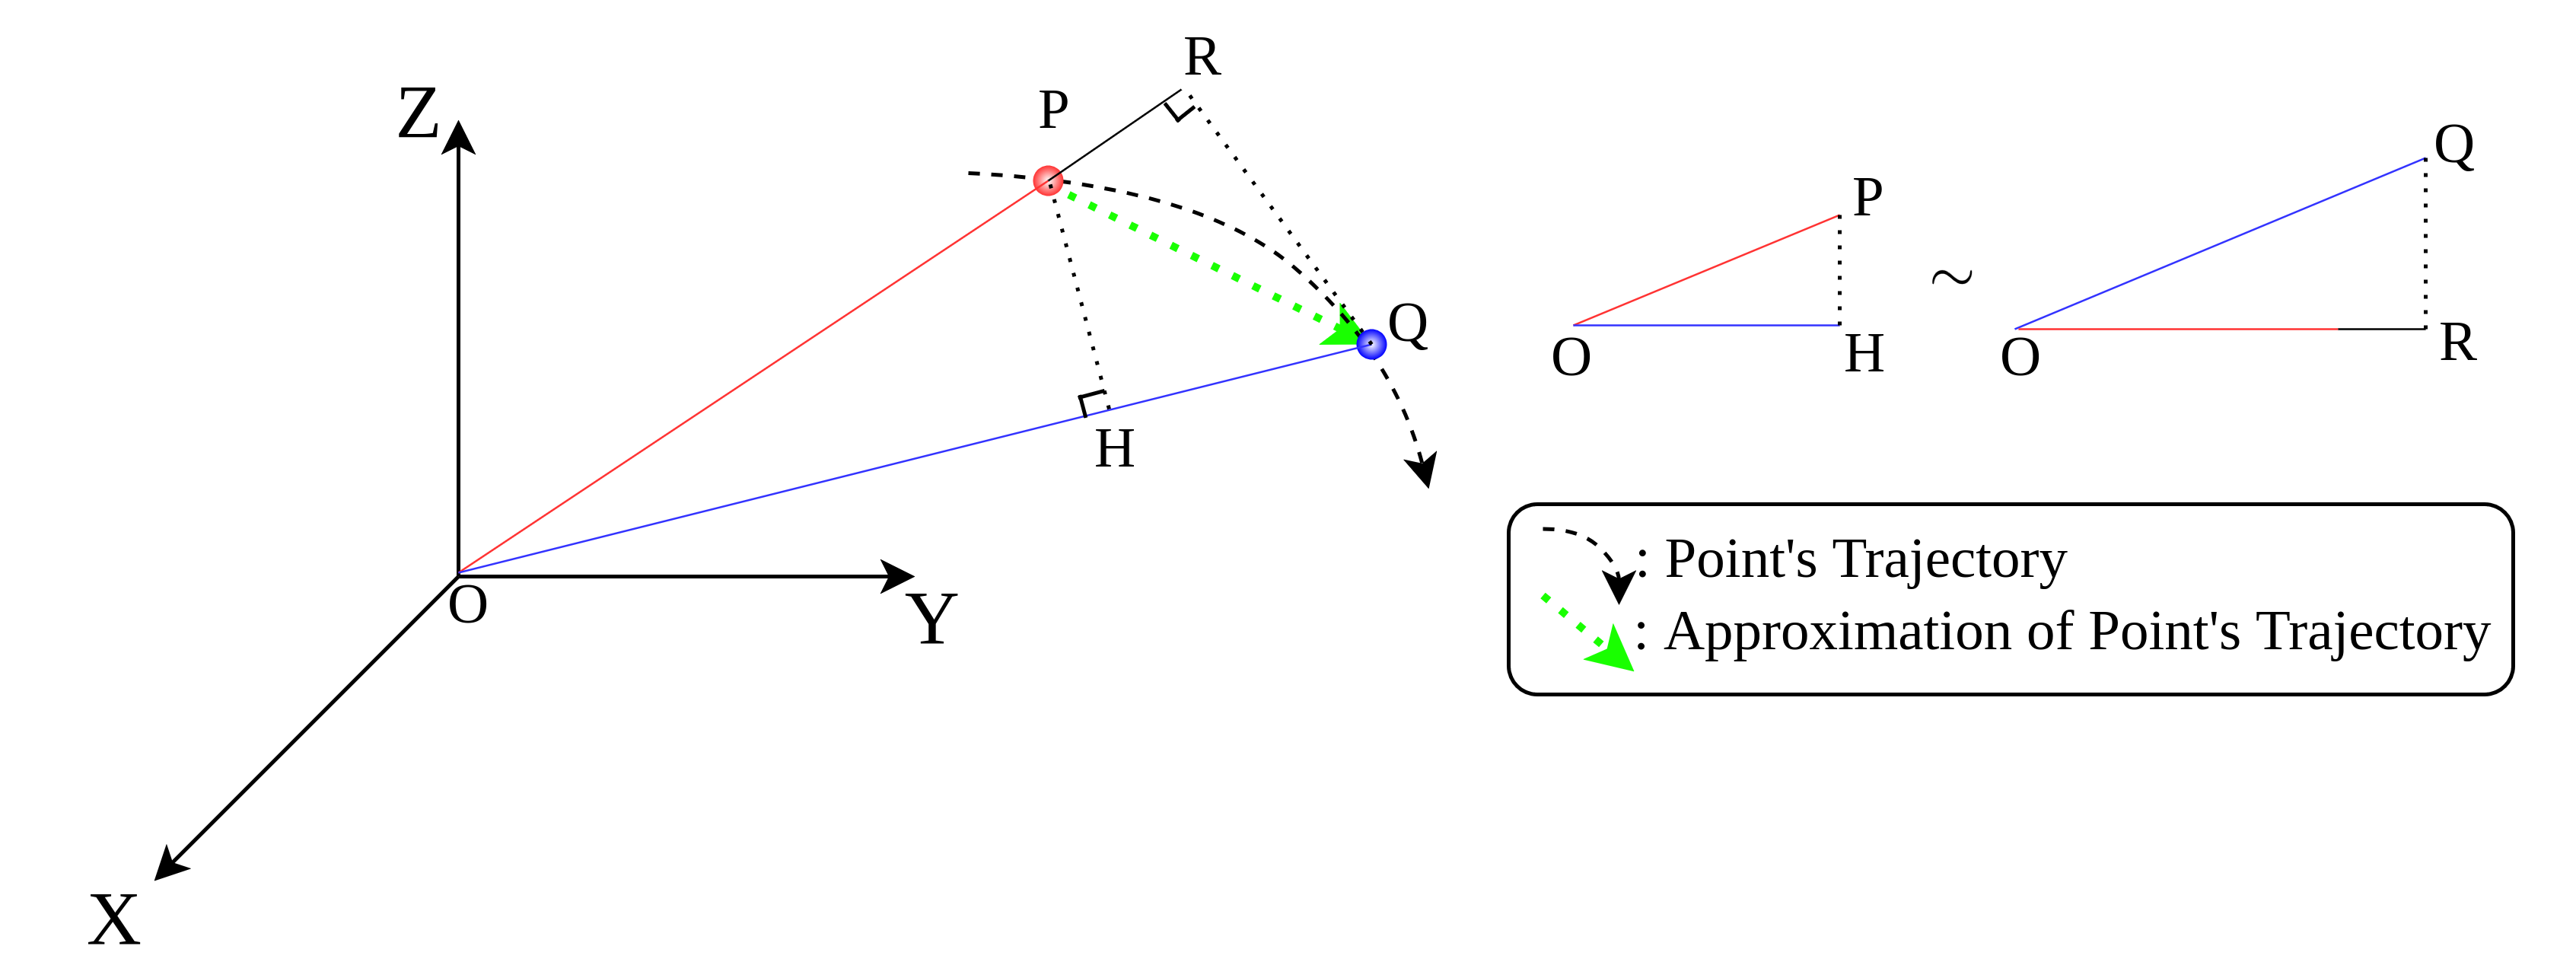
각 점의 거리 r과 방사 방향 속도 v, 스캔 간 시간 ΔT를 결합합니다. 정적 장면과 작은 회전이라는 근사 조건에서, 실제 대응점은 아래의 관계를 만족합니다. 왼쪽은 source 점, 오른쪽은 target 점에서 각각 계산할 수 있어, 3차원 최근접점 탐색을 1차원 값의 매칭으로 바꿀 수 있습니다.
대응점을 한 번 찾은 뒤 공간 거리와 Doppler 기준으로 이상치를 걸러내고, 남은 대응점으로 강체 변환을 추정합니다. 반복적으로 대응점을 다시 찾는 루프 없이 스캔을 정합하는 것이 핵심입니다.
결과와 적용 조건
희소·준밀집 4D Radar와 밀집 4D LiDAR 실험에서 계산 효율과 반복 구조 환경에서의 강건성을 확인합니다. 다만 모든 조건에서 가장 정확한 방법이라는 뜻은 아닙니다. 큰 회전, 긴 스캔 간격, 많은 동적 물체는 가정을 약화시켜 성능을 떨어뜨릴 수 있습니다. 논문은 Doppler 대응점을 기존 ICP와 결합하는 방식도 다룹니다.
English summary
The problem
Spatial proximity can be ambiguous in sparse scans and repetitive scenes. Standard ICP repeatedly updates nearest-neighbor matches and the estimated pose. This work instead uses the radial velocity measured by 4D radar and FMCW LiDAR to establish correspondences.
The approach
Range, Doppler velocity, and the time between scans define a scalar correspondence relation. Under the static-scene and small-rotation assumptions, matching these values provides a one-dimensional alternative to searching for spatial neighbors. The method finds correspondences once, rejects outliers using spatial and Doppler thresholds, and estimates the rigid transformation.
Findings and scope
Experiments across sparse and semi-dense radar and dense LiDAR demonstrate computational savings and resilience to repetitive geometry. Accuracy depends on motion and scene conditions: larger rotations, longer scan intervals, and moving objects can undermine the assumptions. The paper also explores combining Doppler correspondences with iterative registration.
Inside the paper · 주요 Figure
요약 및 Figure 출처 / Summary and figures: Kim et al., Doppler Correspondence, RSS 2025. Figures reproduced from the authors’ paper; original numbering retained. 그림을 클릭하면 원본 크기로 볼 수 있습니다.